PhD Candidate · Aerospace Engineering · Texas A&M University

Koya Yamamoto

I build the guidance, navigation, and control that lets spacecraft fly precisely — from cislunar trajectory optimization to high-precision state estimation, validated from theory all the way to hardware.

↓
01

About

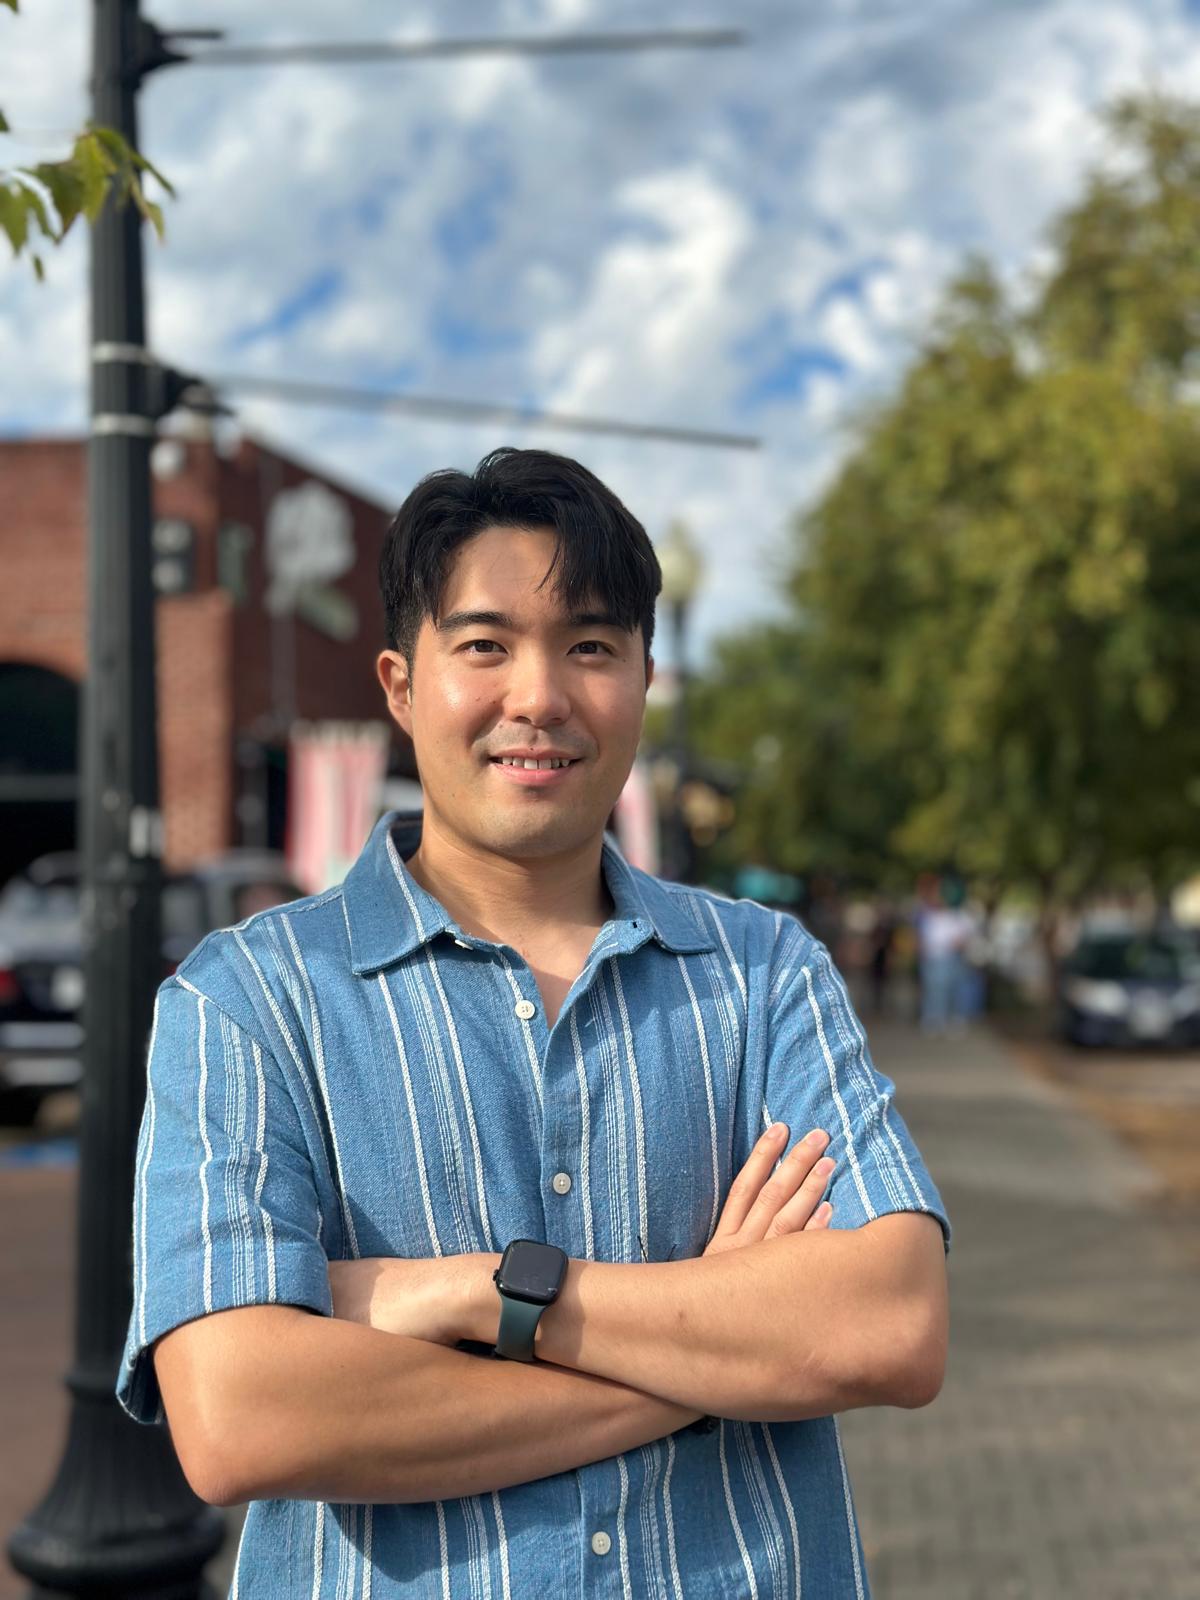
Portrait of Koya Yamamoto
🧑‍🚀

I'm a PhD candidate in Aerospace Engineering at Texas A&M University (GPA 4.0/4.0), working at the intersection of control theory, state estimation, and trajectory optimization. My research focuses on making spacecraft maneuvers fast, accurate, and robust to uncertainty.

Much of my work centers on cislunar trajectory optimization and model-predictive control, high-precision numerical differentiation for dynamical systems, and estimation techniques that hold up in real, noisy environments. I care deeply about closing the gap between elegant theory and flight-ready software — including hardware-in-the-loop validation on real embedded platforms. These same guidance, navigation, and control methods carry over naturally beyond spacecraft — to drones, automotive, and robotics systems — and those are areas I'm especially excited to work in.

Before Texas A&M, I earned my BS in Mechanical Engineering from Waseda University in Tokyo, and I've since worked on navigation systems at VectorNav and spacecraft landing dynamics at JAXA/ISAS.

  • 🎓 PhD @ Texas A&M
  • 📊 GPA 4.0 / 4.0
  • 🛰️ GNC & Estimation
  • 🌏 Tokyo → College Station
02

Research Projects

My work spans cislunar trajectory optimization, optimal control under uncertainty, high-precision differentiation, and state estimation. Below are selected projects across those areas. Detailed write-ups and slides coming soon.

🪐

Uncertainty Propagation with Complex-Step STTs

High-order complex-step (CX) state-transition tensors that propagate orbital uncertainty under J2 and atmospheric drag — built without a closed-form flow map. Benchmarked across five coordinate sets (Cartesian, COE, MEE, GEqOE, MRP-MEE) against Monte Carlo, matching its accuracy at 1–2 orders of magnitude lower cost.

Complex-StepSTTsAstrodynamics
🌙

Cislunar Trajectory Correction via Nonlinear MPC

Nonlinear model-predictive control (NMPC) that corrects cislunar transfers in the CR3BP under impulsive-maneuver uncertainty, blending pre-planned impulsive burns with low-thrust NMPC corrections. On a southern L2 halo-to-halo transfer it holds sub-kilometer tracking error at ~315 m/s total Δv, with IPOPT running up to 2× faster than MATLAB's fmincon.

MPCCasADiTrajectory Opt
🧮

NLP Solver & Derivative-Accuracy Study

A systematic comparison of two NLP solvers (MATLAB's fmincon and IPOPT) and three derivative methods — finite-difference, complex-step (CX), and analytical — on a minimum-Δv multi-impulse transfer between two Distant Retrograde Orbits in the CR3BP. The CX method nearly matches analytical derivatives while being far easier to implement, and IPOPT converges faster than fmincon with accurate derivatives.

NLP SolversIPOPTfmincon
∂

High-Precision Partial Derivative Approximation

An extension of the complex-step method for partial derivatives of smooth vector functions of n variables, with novel multivariable second- and higher-order formulas. In 64-bit arithmetic it reaches ~15-digit accuracy for first derivatives, 10–13 for second, and 5–8 for third — with no operator overloading (MATLAB/Python/C++), far cheaper than automatic differentiation and more accurate than finite differences.

Numerical MethodsMATLAB
🛰️

Multi-Impulse Cislunar Trajectory Optimization with Jacobian Coloring

A multiple-shooting, multi-impulse framework for minimum-Δv cislunar trajectory optimization, combining impulse regularization, complex-step sensitivities, and Jacobian coloring. By exploiting the constraint Jacobian's sparsity, coloring cuts per-iteration function evaluations (52 → 14 for a five-node transfer) for a ~2× speed-up, generating families of locally-optimal transfers between southern L2 halo orbits — the best exploiting a lunar gravity assist.

Trajectory OptJacobian ColoringCislunar
📡

Attitude Estimation from Accelerometers

A gyro-free method for determining a spacecraft's angular velocity and acceleration from an array of triaxial accelerometers, using linear least squares to estimate functions quadratic in angular velocity. Establishes minimum sensor requirements, a way to resolve the spin-axis sign, and a linearized covariance approximation that matches Monte-Carlo results.

Least SquaresCovariance AnalysisEstimation
🧭

Real-Time Navigation Smoothing

Post-Kalman smoothing algorithms that doubled state-estimation accuracy for real-time navigation, plus high-precision geoid-undulation modeling with the EGM2008 gravity model. (VectorNav)

Kalman FilterNavigationEGM2008
🛬

Lunar-Landing Sloshing Dynamics

Physics-based mass-spring-damper models of propellant sloshing during lunar landing, with stability analysis and landing-gear control laws to prevent overturn. (JAXA/ISAS)

DynamicsSimulinkControl
🎈

Stratospheric-Balloon Experiment

Alignment-monitoring payload designed and prototyped for stratospheric flight, with structural analysis validating survival in near-space conditions. (Waseda)

FemapNastranSolidWorks
03

Experience

Research and engineering roles across academia and industry, in the US and Japan.

Aug 2022 – Present

Graduate Research Assistant

Texas A&M University · College Station, TX

  • Designed nonlinear and shrinking-horizon MPC for trajectory correction under maneuver uncertainty on cislunar orbit transfers.
  • Developed the Complex-Step (CX) differentiation method for highly accurate, efficient derivatives of dynamic systems.
  • Integrated graph-coloring into trajectory optimization for a 2× speedup in real-time path planning, validated in hardware-in-the-loop testing on Arduino & Raspberry Pi.
  • Built a system-identification method approximating complex multidimensional functions with analytical forms; now developing tube-based MPC for cislunar transfers.
May – Aug 2023

Navigation Engineer Intern

VectorNav Technologies · Dallas, TX

  • Developed smoothing algorithms for post-Kalman filtering, achieving a 2× improvement in state-estimation accuracy for real-time navigation.
  • Created high-precision geoid-undulation algorithms using the EGM2008 model, deriving recursive formulas for Legendre polynomials.
Summer 2021

Technical Trainee

JAXA / ISAS · Kanagawa, Japan

  • Modeled liquid-sloshing effects on spacecraft lunar-landing dynamics with physics-based mass-spring-damper models.
  • Determined system stability boundaries and failure modes through simulation, and proposed control laws for landing-gear systems to prevent overturn.
2020 – 2021

Undergraduate Research Project

Waseda University · Tokyo, Japan

  • Designed stratospheric-balloon experiments to validate an alignment-monitoring system.
  • Ran structural analysis for stratospheric conditions (Femap, Nastran) and built & tested physical prototypes.
04

Publications

Peer-reviewed journal and conference papers. Google Scholar ↗

  1. Uncertainty Propagation with Complex-Step State Transition Tensors for Perturbed Orbital Dynamics

    K. Yamamoto, J. L. Junkins, S. Shrivastava

    Journal of Guidance, Control, and Dynamics (JGCD). Under review

  2. Nonlinear MPC for Cislunar Trajectory Correction Under Impulsive Maneuver Uncertainties: A Computational Performance Analysis

    K. Yamamoto, E. Taheri, J. L. Junkins

    2026 American Control Conference (ACC), IEEE, 2026.

  3. Jacobian Coloring for Multi-Impulse Cislunar Trajectory Optimization

    K. Yamamoto, E. Taheri, J. L. Junkins

    Aerospace Science and Technology, Vol. 180, Art. no. 113985, 2027.

  4. Advances in High-Precision Partial Derivative Approximation for Functions of n Variables

    K. Yamamoto, J. L. Junkins

    The Journal of the Astronautical Sciences, 73(3), 2026.

  5. Comparison of NLP Solvers and Derivative Accuracy for Solving Multi-Impulse Cislunar Trajectory Optimization Problems

    K. Yamamoto, E. Taheri, J. L. Junkins

    2025 American Control Conference (ACC), IEEE, July 2025, pp. 3807–3812.

  6. Advancing Complex Differentiation: Applications to the State Transition Matrix

    K. Yamamoto, P. Kelly, J. L. Junkins

    AAS/AIAA Astrodynamics Specialist Conference, Broomfield, CO, Aug. 2024.

  7. Covariance Analysis of Attitude and Angular Rate Estimation Using Accelerometers

    K. Yamamoto, P. Kelly, M. Majji, F. Guzmán

    AAS/AIAA Astrodynamics Specialist Conference, Big Sky, MT, Aug. 2023.

05

Skills & Education

Education

Ph.D., Aerospace Engineering

Texas A&M University · 2022 – Present · GPA 4.0/4.0

Random Dynamical Systems · Space Domain Awareness · Celestial Mechanics · Spacecraft Dynamics · Optimal Attitude & Orbital Maneuvers · Estimation of Dynamic Systems

B.S., Mechanical Engineering

Waseda University, Tokyo · 2018 – 2022 · GPA 3.6/4.0

Mechatronics · Fluid Dynamics · Satellite Design · C Programming

Languages

Japanese — Native English — Fluent Italian — Advanced Spanish — Beginner

Technical Skills

Programming

MATLABSimulinkPythonC++

Control & Estimation

MPCPIDOptimal ControlEKF / UKFLeast-Squares Estimation

Optimization

IPOPTSNOPTfminconCasADi

CAD & Analysis

SolidWorksAutoCADFemapNastran

Hardware

ArduinoRaspberry Pi
06

Get in touch

Interested in collaborating on spacecraft GNC, or in my work for a role? I'd love to hear from you.

or reach me directly at koyayamamoto123@gmail.com